Equine-Inspired Vision System: Partially Self-supervised 360° Stereo Panoramic Depth Estimation
Han Yu, Jianfeng Li, Shigang Li
Asian Conference on Computer Vision (ACCV) 2026 · Project HorseVision
Overview
A horse sees the world through two eyes set on either side of its head: together they cover almost the full 360°, and their fields of view overlap in a narrow binocular region. HorseVision mimics this with a back-to-back dual-fisheye camera — a left eye and a right eye — and estimates 360° stereo panoramic depth for both eyes.
The two fisheye views are predicted by a shared Depth-Anything-V2 encoder, fused into equirectangular panoramas by geometric splatting, and refined by a lightweight ViT (MiniDA3). Self-supervision comes from the binocular overlap between the two lenses: each view is warped into the other using the predicted depth, and the photometric agreement yields a per-pixel confidence map.
Sample data
Sample inputs shipped in test_imgs/ with their ground-truth depth, shown for both eyes. Drag the slider on each image to compare RGB (left) with depth (right).
Indoor
Max depth 20 m. Depth: jet colormap, 0–20 m (blue = near, red = far, black = invalid).
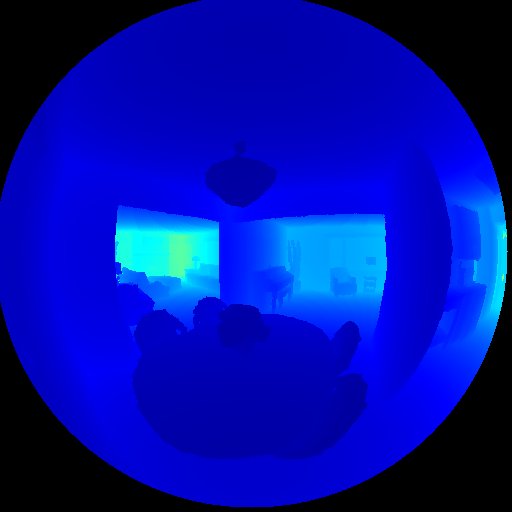
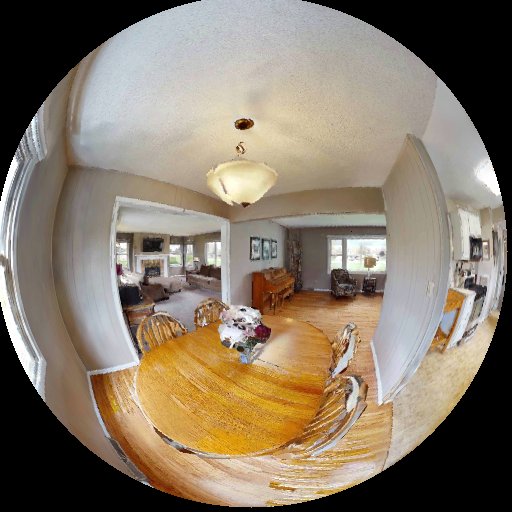 RGBDepth
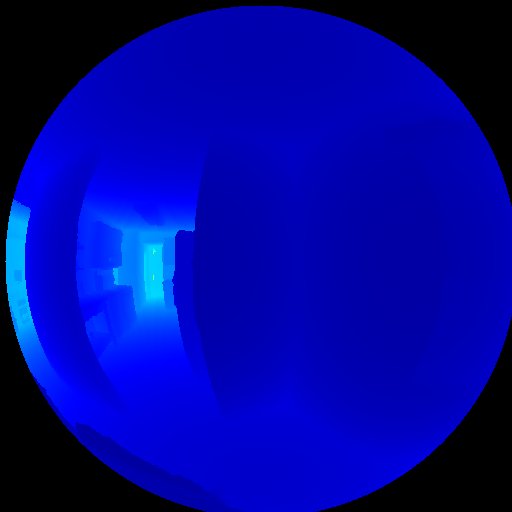
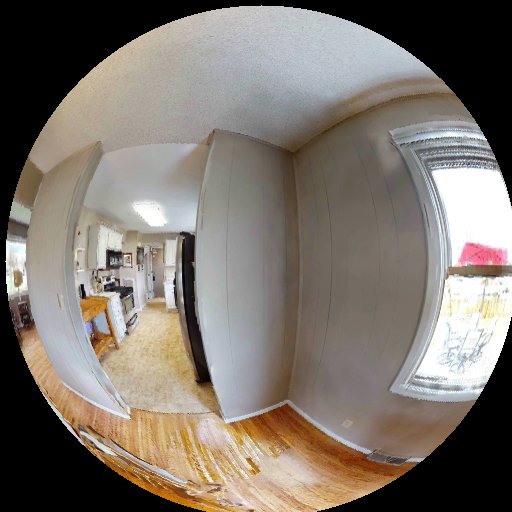 RGBDepth
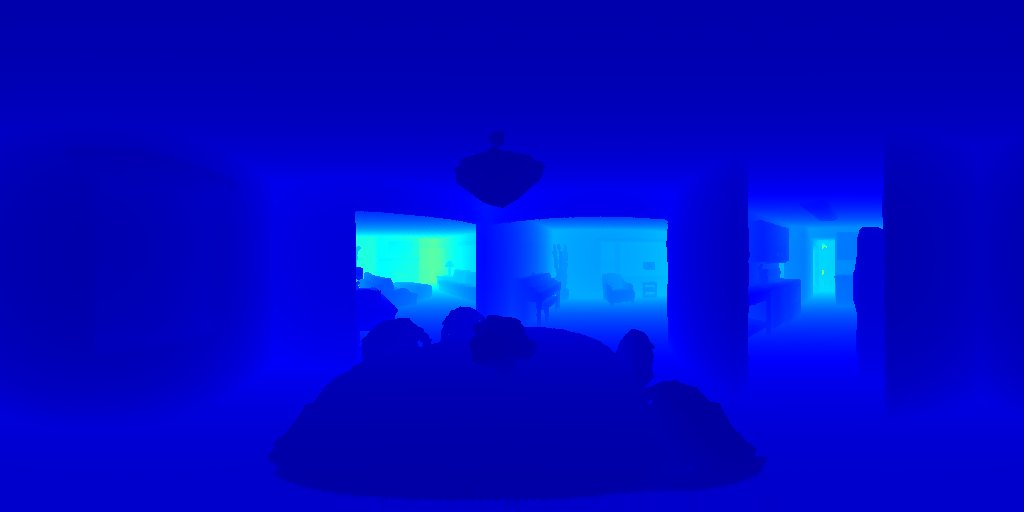
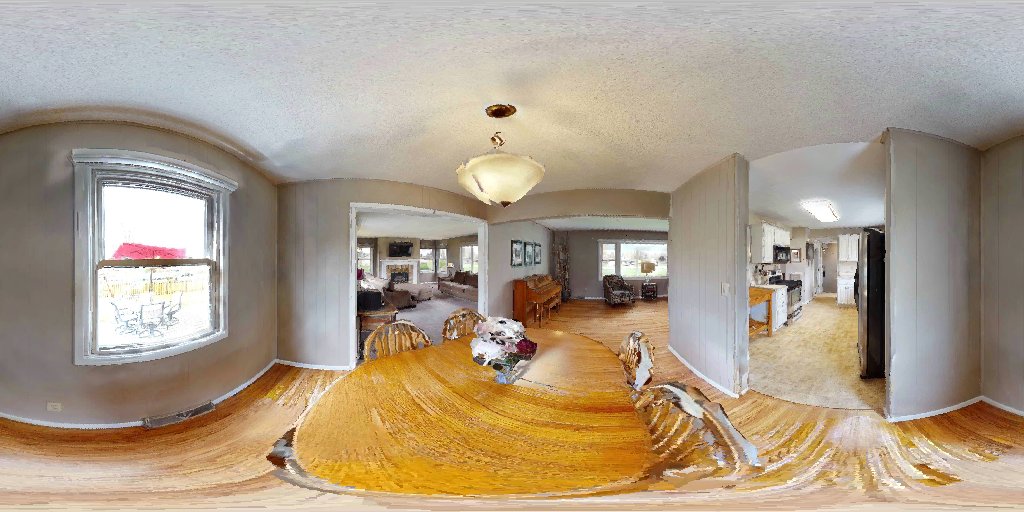 RGBDepth
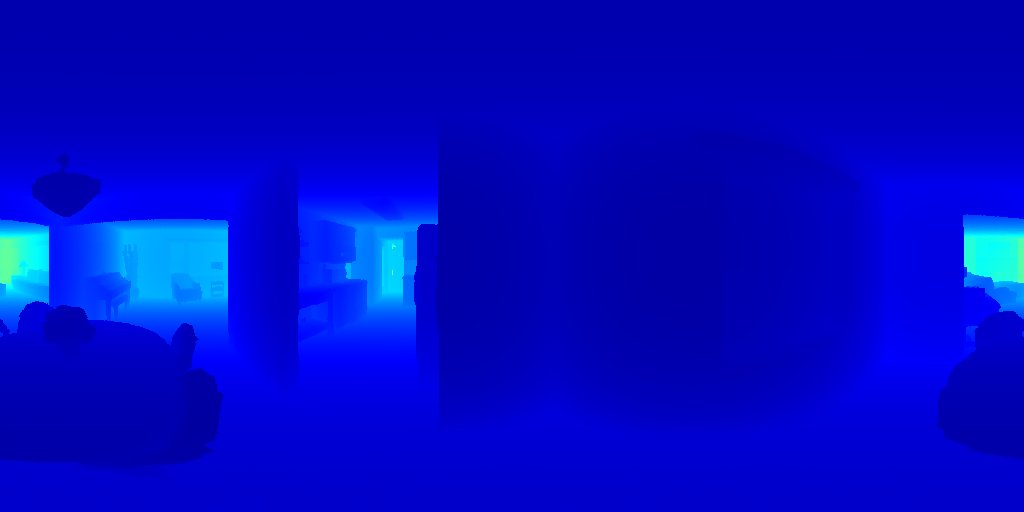
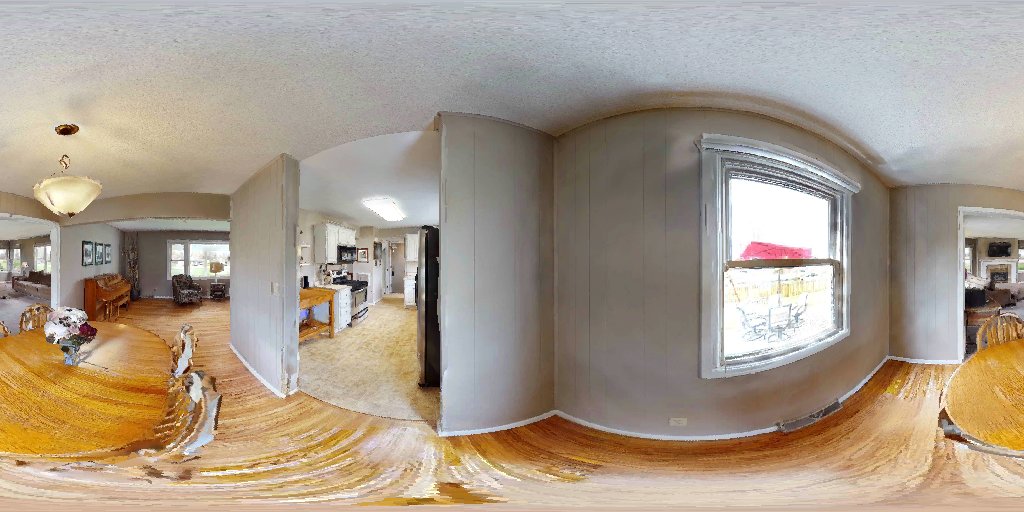 RGBDepth
Outdoor
Max depth 80 m (CARLA). Depth: jet colormap, 0–80 m (blue = near, red = far, black = invalid).
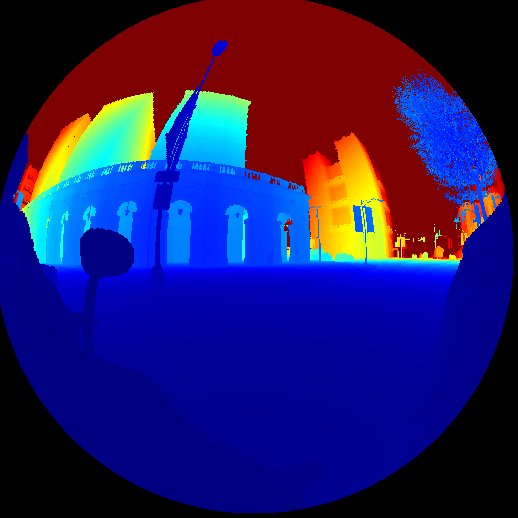
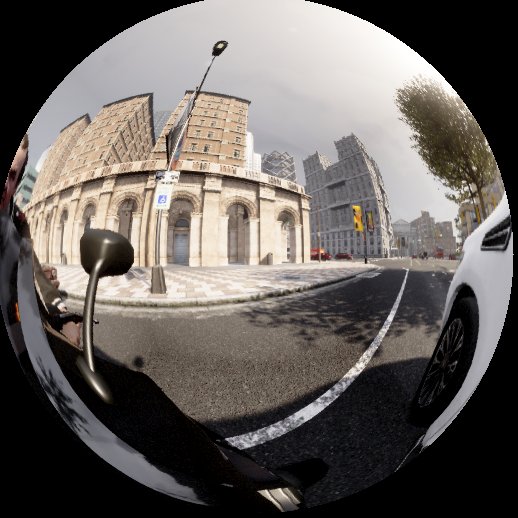 RGBDepth
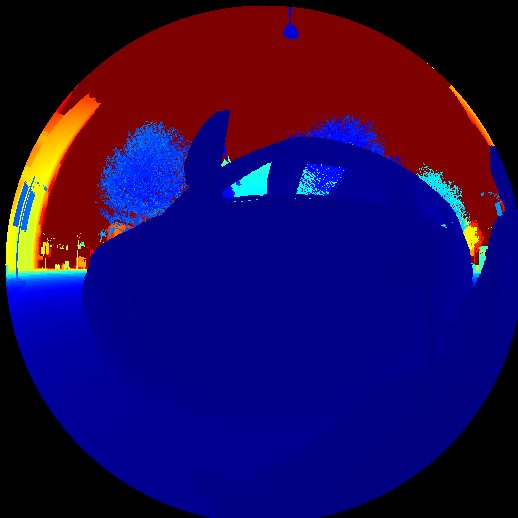
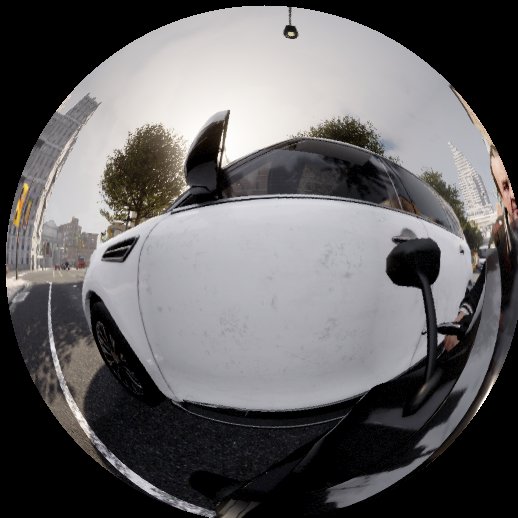 RGBDepth
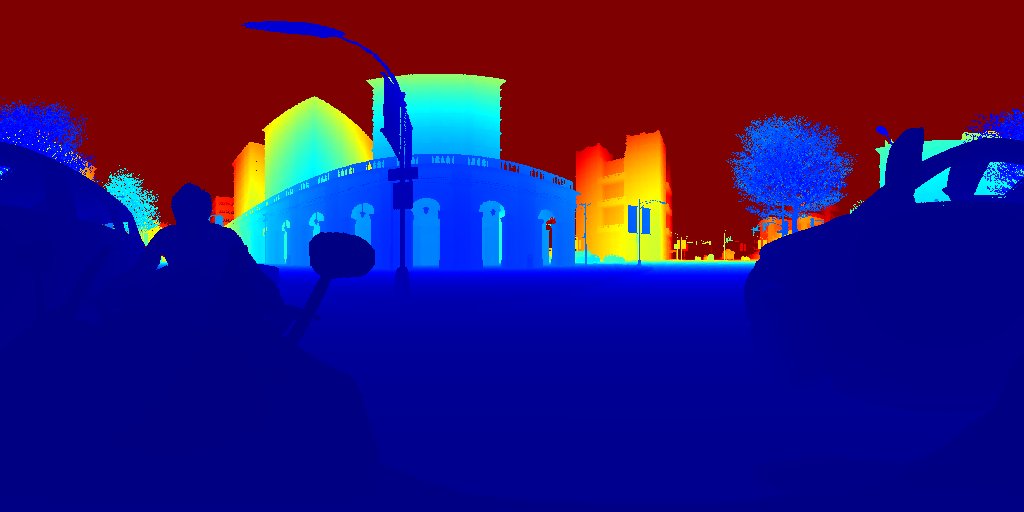
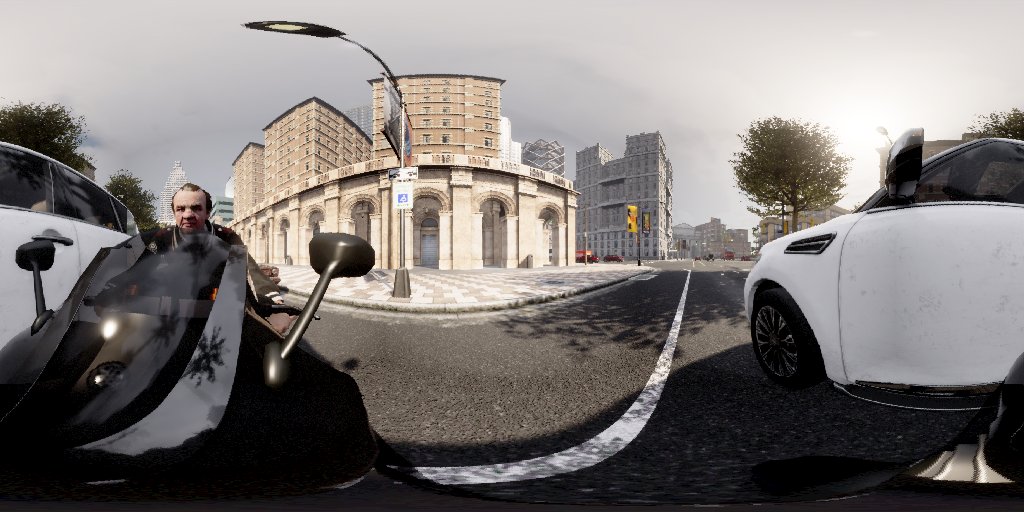 RGBDepth
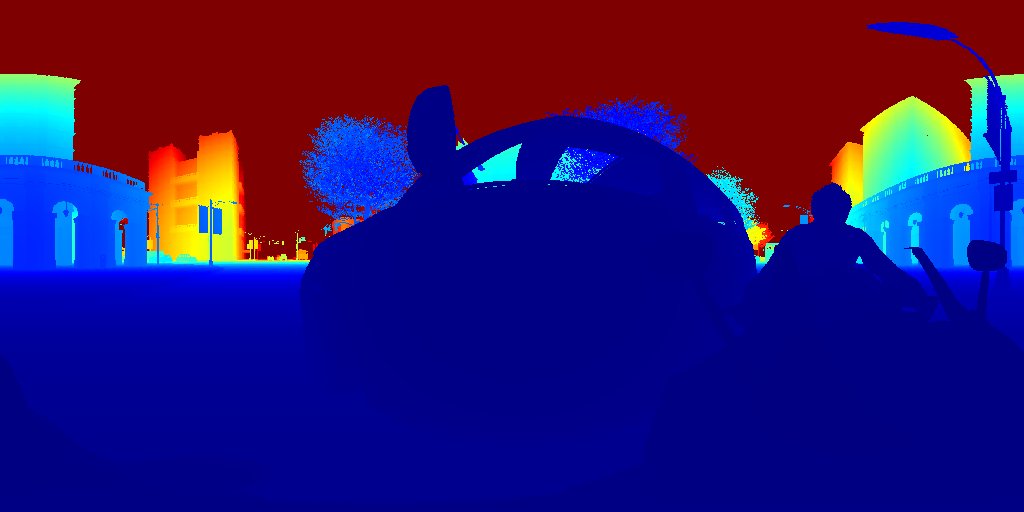
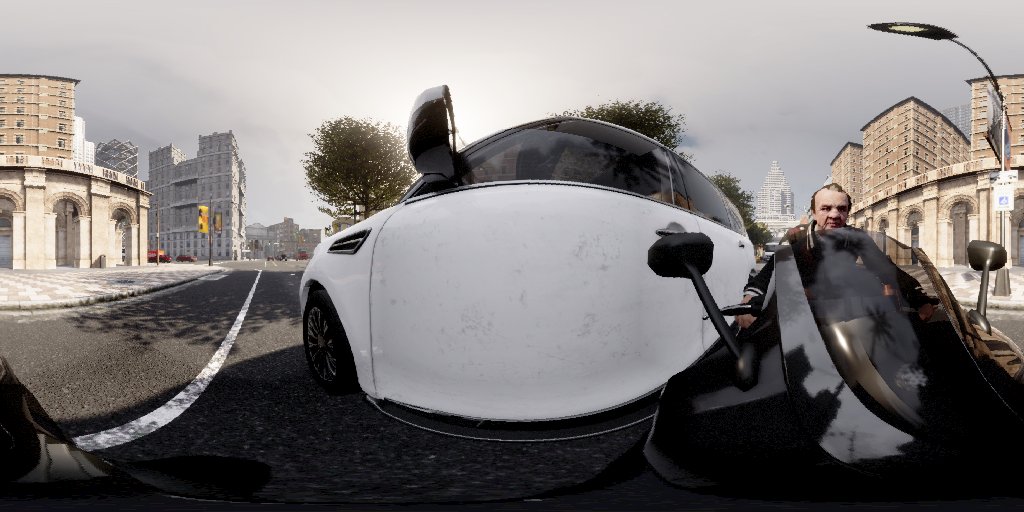 RGBDepth
At a glance
| Input | 2 × fisheye RGB (518 × 518) |
|---|---|
| Output | Panoramic depth (518 × 1036), per-view fisheye depth, confidence maps |
| Peak GPU memory | 1.14 GB |
| End-to-end runtime | 3.9 s including model loading (RTX 4090) |
| Scenes | Indoor (max 20 m, Structured3D / HM3D) · Outdoor (max 80 m, CARLA) |
Quick start
git clone https://github.com/koshokai/HorseVision.git
cd HorseVision
git clone https://github.com/DepthAnything/Depth-Anything-V2.git
python download_models.py --scene outdoor
python test_single_conf.py
See the README for requirements, model zoo and configuration.
Citation
@inproceedings{
  yu2026equineinspired,
  title={Equine-Inspired Vision System: Partially Self-supervised 360{\textdegree} Stereo Panoramic Depth Estimation},
  author={Han Yu and Jianfeng Li and Shigang Li},
  booktitle={Eighteenth Asian Conference on Computer Vision},
  year={2026},
  url={https://openreview.net/forum?id=Koe6h9l5w1}
}